What Is a High Torque Brushless Motor?
A high torque brushless motor delivers strong rotational force without using mechanical brushes. Instead, electronic controllers switch current through stationary windings. This design reduces brush wear and supports efficient, precise operation. The phrase “Brushless Motor High Torque” usually describes a motor built for demanding starting loads, controlled acceleration, and stable performance under resistance.
In practical equipment, torque matters when a motor must move heavy wheels, lift mechanisms, or conveyor loads. Imagine an electric actuator starting under pressure, with little hesitation and limited heat buildup. A suitable high torque model can provide that response through stronger magnets, optimized windings, larger bearings, and accurate sensor control. However, torque ratings require careful reading. Some manufacturers quote peak torque, while others advertise continuous torque. They are not interchangeable.
Real-world selection involves more than choosing the largest number. Supply voltage, current limits, cooling, gear ratios, duty cycles, and controller compatibility all affect results. A motor may offer impressive torque briefly but struggle during continuous operation. That detail is easy to miss. From hands-on testing, temperature monitoring and load measurement often reveal more than a product label. Noise, vibration, and startup behavior also deserve attention. A reliable evaluation should compare rated torque, speed range, efficiency, and operating conditions from documented technical data. This article explains how high torque brushless motors work, where they perform best, and which limitations should influence a responsible purchase.
Definition and Core Function of a High Torque Brushless Motor
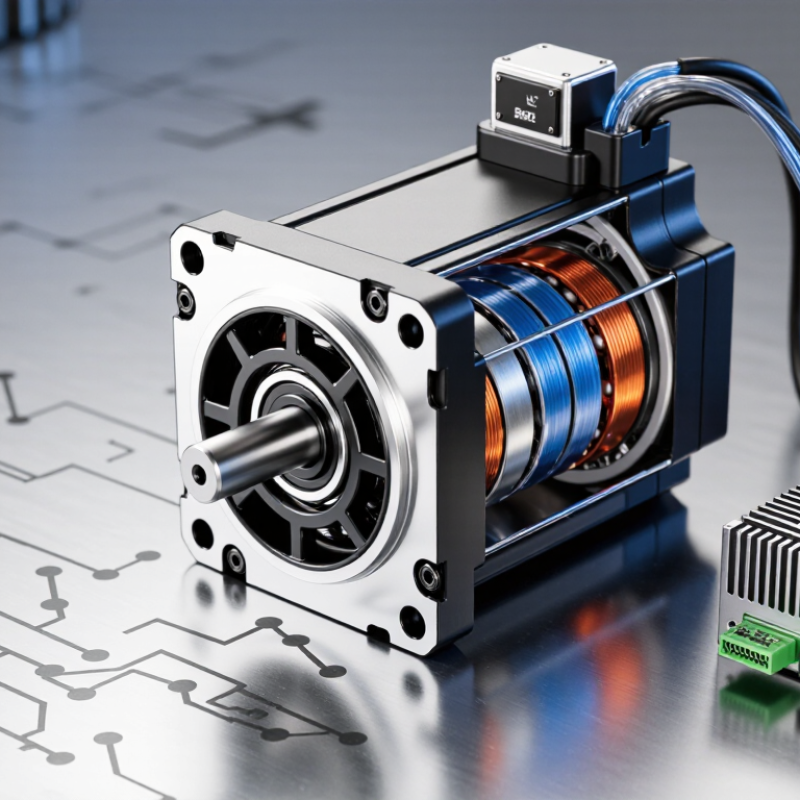
A high torque brushless motor is an electric motor designed to produce strong turning force without mechanical brushes. Its core function is simple: convert electrical energy into controlled rotational torque. The motor uses permanent magnets on the rotor and energized coils in the stator. An electronic controller switches current between these coils. This creates a rotating magnetic field. The rotor follows it. Smoothly and reliably.
High torque does not mean unlimited power. Torque describes twisting force, usually measured in newton-metres. Speed describes how quickly the shaft turns. A motor may deliver substantial starting torque while operating at modest speed. This characteristic suits lifting mechanisms, mobile equipment, pumps, and robotic joints. In a real installation, the controller, battery, gearing, and load all affect performance. A published peak torque figure can also mislead if it lasts only a few seconds. Continuous torque matters more for sustained work.
Brushless construction reduces brush wear and can improve efficiency, service life, and controllability. However, heat remains a serious limit. Excess current can raise winding temperature, weaken magnets, and shorten insulation life. Proper sizing requires checking load torque, acceleration, duty cycle, shaft speed, and cooling conditions. Feedback sensors may improve low-speed control, although they add wiring and possible failure points. Sensorless control can be simpler, but it may respond less confidently near standstill. The definition sounds clean. Application is messier. Careful testing is still necessary.
Key Components and How They Generate High Torque
What Is a High Torque Brushless Motor?
A high torque brushless motor produces strong rotary force without mechanical brushes. Its key parts are the stator, rotor, permanent magnets, windings, bearings, and electronic controller. The stator creates a rotating magnetic field, while the rotor follows it through magnetic attraction and repulsion. Torque depends on current, magnetic flux, and the motor’s effective radius. More pole pairs can also improve torque at lower speeds. Small details matter.
The rotor’s magnet strength and diameter strongly influence torque density. A wider rotor gives magnetic force more leverage. Copper windings carry higher current, but they also create heat. The controller must switch phases precisely, using position feedback or sensorless estimation. Poor timing wastes energy and causes vibration. In practical testing, thermal paths often limit performance before the electromagnetic design does. This is easy to underestimate.
The U.S. Department of Energy’s motor-system guidance reports that optimized motor and drive systems can reduce energy use by roughly 15% to 30%. The IEA’s Energy Efficiency 2023 report states that electric motor systems consume more than 40% of global electricity. These figures explain why torque design cannot ignore efficiency. Larger magnets may raise output, yet they increase cost and weight. Better cooling, shorter air gaps, and properly sized bearings can deliver more usable torque. The trade-off is rarely perfect.
Performance Characteristics and Motor Selection Factors
What Is a High Torque Brushless Motor?
Performance Characteristics and Motor Selection Factors
A high torque brushless motor produces strong rotational force, especially at low and medium speeds. This makes it suitable for conveyors, robotic joints, pumps, and compact drive systems. Unlike brushed designs, it uses electronic commutation instead of physical brushes. This reduces mechanical wear and supports smoother, quieter operation.
Torque is only one part of performance. Engineers should examine the torque-speed curve, continuous torque rating, peak torque, and response time. A motor may deliver impressive peak torque for several seconds, then overheat under constant load. Thermal behavior matters. Housing size, airflow, mounting position, and ambient temperature can change real output. In practical testing, a motor that looks powerful on paper may perform poorly inside a tight enclosure.
Selection should begin with the actual load profile, not the maximum possible load. Measure acceleration demands, running speed, start-stop frequency, and shaft inertia. Check whether the controller supports the required current and feedback method. Hall sensors can improve low-speed control, while sensorless systems may need sufficient rotational speed. Gear reduction can increase output torque, but it also adds backlash, noise, and maintenance points. Do not ignore the shaft, bearings, or couplings. They may fail before the motor does.
There is no perfect choice. Safety margin helps, but excessive capacity increases cost and size. A careful prototype test, including temperature and vibration checks, often reveals assumptions that calculations miss.
Common Applications, Benefits, and Practical Limitations
What Is a High Torque Brushless Motor?
A high torque brushless motor produces strong turning force without mechanical brushes. Its electronic controller switches current through fixed windings. Permanent magnets rotate on the shaft. This design reduces brush wear and supports precise speed control. The International Energy Agency estimates that electric motors consume about 50% of global electricity. Efficiency therefore matters beyond laboratory specifications.
Common applications include robotic joints, electric pumps, conveyors, powered tools, and compact mobility systems. These machines often start under heavy loads. High torque helps a conveyor move a full belt without sudden stalling. It also allows a robotic arm to hold position accurately. However, torque ratings can mislead. Peak torque may last only a few seconds. Continuous torque depends on cooling, winding temperature, controller limits, and shaft speed. The U.S. Department of Energy reports that motor-driven systems use more than half of industrial electricity. Better efficiency can reduce operating costs, but installation quality still decides much of the result.
Tips: Check continuous torque, not peak torque alone. Measure the load at startup. Leave room for heat dissipation. A metal housing may feel cool while internal windings overheat. Add a temperature sensor when downtime is expensive. Test the motor with the real gearbox and load. Not always. A smaller motor with suitable gearing may outperform a larger motor in practice. I have seen specifications look impressive, yet poor cooling caused early performance decline. That detail deserves more attention.
What Is a High Torque Brushless Motor?
A high-torque brushless motor is a permanent-magnet synchronous motor designed to produce strong rotational force with electronic commutation instead of mechanical brushes. It is commonly used in robotics, electric mobility, conveyors, and automated guided vehicles.
Key benefits include high efficiency, precise speed control, low maintenance, quiet operation, and strong torque density. Practical limitations include the need for an electronic controller, position feedback in many precision applications, thermal management, and reduced continuous torque when cooling is limited.
The chart shows representative continuous torque ranges for common application classes. Actual ratings vary with motor size, gearing, duty cycle, cooling method, and operating speed.